

Brown Integrative, General Artificial Intelligence @BrownUniversity
Providence, RI
Joined April 2019
- Tweets260
- Following386
- Followers1.1K
- Likes408

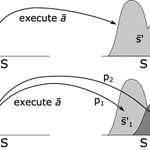
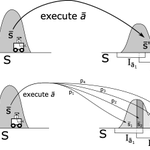




This is how we should be parameterizing skills! System 1 decision making + system 2 planning (with an autoregressive model). These Atari games are a great example of closer to system 1 decision making.

bigAI retweeted

How can robots keep learning once deployed in the messy, ever-changing real world?
Excited to announce our #CoRL2026 workshop on “Robot Learning at Deployment”!
We’ll explore how robots can continually adapt and improve under real-world constraints. 🧵


bigAI retweeted

🤖 Curious about the connection between Task and Motion Planning (TAMP) and robot learning?
📄 Check out our new survey on Learning By and For Task and Motion Planning!
We organize the growing literature on TAMP + learning, introduce a taxonomy of TAMP learning, clarify the state of the art, and highlight promising directions for future research. 🚀
🔗 prpl-group.com/tamp-learning…
bigAI retweeted
Can a world model 🌏 learn to predict how 198 different deformable objects move -- not just one rope or cloth?
That question motivated Deform360: 1,980 real-world interactions captured from 41 synchronized views with bimanual touch sensors, which becomes crucial when vision is occluded.
Accepted at #ECCV2026. 🧵
1/5

Checkout our new #RSS paper on improving BC policies through Online RL !

Can BC policies be quickly improved through real world experience?
Our new #RSS2026 paper proposes Q2RL, a method that bridges BC and RL for on-robot learning.
Q2RL improves BC policies by up to 3.75x with just 1-2 hours of online interaction!
So when life gives you BC, make Q-functions! 🍋
Details in thread 🧵
bigAI retweeted

Residual RL is a powerful strategy for adapting a pretrained base policy, but it struggles when:
❌ Exploration is uncontrolled
❌ Base policies are stochastic
We tackle this in our new RAL paper “Accelerating Residual Reinforcement Learning with Uncertainty Estimation”
(1/5)
If you are also at #HRI2026 this week, please reach out to @IvyXHe, and @jasonxyliu about their work on using multimodal observation, foundation models, and POMDP to enable robots to reason over uncertainty about the task and the environment!

Check out our #HRI2026 paper on using multimodal observation, foundation models, and POMDP to enable robots to reason over uncertainty about the task and the environment!
If you are also at HRI, please reach out for a chat!
bigAI retweeted

🤖 How can we enable robots to solve complex, multi-step manipulation tasks without a single demonstration or any task-specific training?
Introducing NovaPlan: a hierarchical framework for zero-shot long-horizon manipulation. It unifies closed-loop video language planning with grounded execution, allowing robots to “imagine” visual plans, execute robustly, and autonomously recover from failures. [1/5]
🔗 Project page: nova-plan.github.io/
#EmbodiedAI #Robotics #Manipulation #FoundationModels
bigAI retweeted
Thrilled to announce that NovaFlow has been accepted to #ICRA2026! See you in Vienna🚀
NovaFlow is ready for deployment on a local A100/H100 or smaller GPUs via API.
💻 Check out the code here: github.com/bdaiinstitute/Nov…


🤖What if a robot could perform a new task just from a natural language command, with zero demonstrations?
Our new work, NovaFlow, makes it possible! We use pre-trained video generative model to create a video of the task, then translate it into a plan for real-world robot execution.
1/6
#Robotics #AI #ZeroShot #Manipulation
bigAI retweeted
Big thanks to @RoboPapers @chris_j_paxton & @micoolcho for the invite to discuss NovaFlow 🌊, accepted by #ICRA2026!
We’re pushing the boundaries of zero-shot manipulation by leveraging the power of video models in a modular framework.
Code dropping soon! 🚀

The holy grail of robotics is to be able to perform previously-unseen, out-of-distribution manipulation tasks “zero shot” in a new environment. NovaFlow proposes an approach which (1) generates a video, (2) computes predicted flow — how points move through the scene — and (3) uses this flow as an objective to generate a motion. Using this procedure, NovaFlow generates motions in unseen scenes, for unseen tasks, and can transfer across embodiments. To learn more, we are joined by @Hongyu_Lii and @jiahuifu_carol from RAI.
Watch Episode #63 of RoboPapers with @chris_j_paxton and @micoolcho now to learn more!
bigAI retweeted

Our new paper develops robots that don’t just complete tasks: they anticipate how their actions impact what comes next.
Example: when putting objects away, organizing them neatly isn’t just aesthetic—it makes future retrieval faster and easier. 📝🧵👇
bigAI retweeted

Learning accurate World Models for long horizon planning is hard.
So what minimal aspect of world dynamics must a model capture to achieve complex goals?
We find a simple and effective solution in our #ICLR2026 paper, which we will present as an Oral at @worldmodel_26.
(1/n)
The result is an abstract MDP, constructed in a principled way while leveraging the power of neural nets. Planning can now take place over this abstract MDP using planners ranging from value iteration to classical planners. 7/8
Skill-Driven Neurosymbolic State Abstractions, led by Alper Ahmetoglu @alperahmetoglu, Steven James, Cam Allen @camall3n, Sam Lobel, David Abel @dabelcs, and George Konidaris. Check out our poster on Wednesday at #413 between 4:30-7:30. 8/8 openreview.net/forum?id=ggP2…
