



Pinned Tweet
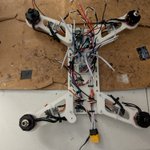
I developed a quadcopter with a custom flight controller, programmed in Python (@micropython), that can efficiently run on a $4 @Raspberry_Pi Pico microcontroller!
Check it out: github.com/TimHanewich/Centa…

Minor upgrade to Centauti's airframe.
Arm now has a "U" cut, no longer a "O" cut, allowing wires to pass through. Much easier to swap out a broken arm!

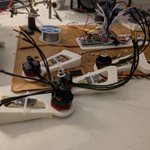
Some more test flying from yesterday. Putting this new onboard PCB through some more flight time for durability testing.
fullstackflight.com
The Roadster they brought out on stage was not the "rocket" variant, just the normal road car with suction fans.


Tim Hanewich retweeted

Please resist the urge to mock the mathematicians struggling through this moment. Whatever your field, your expertise, your passion, you too shall one day experience what they are going through. And when you remember your words, you will feel remorse.
Final chapter of Full Stack Flight! Building your own quadcopter costs more than buying one, that's where the learning is. What's next: better angle estimation, new flight modes, and a custom PCB.
medium.com/@timhanewich/full…
#FullStackFlight

Tough day. Completed assembly of Centauri v2 only to have the rear left ESC malfunction. It may have burned up during assembly (too much exposure to soldering iron?)


Centauri logs telemetry every flight: battery, actual vs desired pitch/roll/yaw, motor output. Chapter 8: the Python (@ThePSF) tooling that unpacks it, and a real crash it helped me diagnose.
medium.com/@timhanewich/full…
#FullStackFlight

So 10th grade geometry ended up coming in handy. At least as long as I don't know how to automate this in Blender.


Chapter 7: the software that turns "pilot moves joystick" into "drone changes pitch." Reads @Xbox controller inputs, packs control packets 20x/sec, displays telemetry back. Any lag shows up instantly in the air.
medium.com/@timhanewich/full…
#FullStackFlight


Skipped custom transmitter hardware. Instead: an @Xbox controller + laptop + a cheap radio module = a fully capable, bidirectional transmitter. Chapter 6: how that platform works.
medium.com/@timhanewich/full…
#FullStackFlight

The effort continues!


Another (minor) addition to the Centauri ecosystem: Link Monitor
Just a small handheld device to check reception at range of the control commands being sent out by the transmitter.
Wiring diagram done. Now to design the device.
github.com/TimHanewich/centa…

Programming the flight controller was, hands down, the hardest part of this build. Picked @micropython over C/C++ for readability. Chapter 5: the boot sequence, the PID loop, and the sensor reads.
medium.com/@timhanewich/full…
#FullStackFlight
