

AI Researcher | PhD @MIT_CSAIL | formerly @WeizmannScience @HebrewU
Joined December 2020
- Tweets28
- Following179
- Followers436
- Likes92



I'm at #NeurIPS2024 presenting our work on:
🤖 Few-shot robot task learning via generative modeling
⚛️ Extrapolation in materials science
I’m also on the job market this year! Let’s chat about industry research opportunities, distribution shift in ML, and AI4Science. 🧵
Few-shot robot task learning via generative modeling
🪧 Poster #6602
🕟 Thursday, 4:30-7:30pm PT
📍 West Ballroom A-D
teapaw.org/avivnet/status/1865059…

Learning new tasks with imitation learning often requires hundreds of demos. Check out our #NeurIPS paper in which we learn new tasks from few demos by inverting them into the latent space of a generative model pre-trained on a set of base tasks.
avivne.github.io/ftl-igm/
Extrapolation in materials science
🗣️ Spotlight presentation at AI4Mat
🕝 Saturday, 2:42-2:54pm PT
📍 West Meeting Room 211-214
teapaw.org/NofitSegal/status/1864…

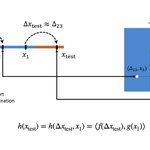
Zero-shot extrapolation for out-of-distribution (OOD) chemical property prediction is an important step towards high-performance materials discovery. Check out our spotlight at the #NeurIPS AI for Accelerated Materials Design Workshop! openreview.net/pdf?id=Hkfnue…

Tasks are often defined by a policy, reward, or trajectory, requiring retraining for new tasks. Inspired by few-shot visual concept learning via inverting generative models, we infer tasks represented as latent vectors without retraining.

1
8
1,001
We evaluate our approach extensively and demonstrate that we successfully learn novel tasks and generate corresponding agent plans and motion in (1) unseen configurations and (2) in composition with training tasks.
Joint work with awesome collaborators @du_yilun, @BronarsToni, @jyo_pari, Josh Tenenbaum @MITCoCoSci, @tianminshu and @pulkitology.
Drop by our poster Thu, 4:30-7:30pm PT, West Ballroom A-D #6602! neurips.cc/virtual/2024/post…
7
576
Learning new tasks with imitation learning often requires hundreds of demos. Check out our #NeurIPS paper in which we learn new tasks from few demos by inverting them into the latent space of a generative model pre-trained on a set of base tasks.
avivne.github.io/ftl-igm/
Join us tomorrow to learn more about the role of LLMs in robot social intelligence!

Join us at the #RSS2024 Workshop on Social Intelligence in Humans and Robots on July 19 (1:45 - 6 pm, Netherland time). We have exciting talks covering diverse topics in robotics, AI, & cog sci. Schedule & Zoom available at: social-intelligence-human-ai…
Visual scene analysis is challenging due to the complexity of objects, properties, and relations in natural scenes. Our PNAS paper pnas.org/doi/10.1073/pnas.22… proposes a goal-directed model for scene analysis that focuses on partial scene structures of interest.

We further show across several tasks that TD guidance is crucial for noncombinatorial and combinatorial generalization in the low and high data regimes.

Excited that this amazing project I was fortunate to be part of during my time at @WeizmannScience is now published!
Led by Shimon Ullman, Liav Assif, and Alona Strugatski, and in collaboration with Ben-Zion Vatashsky, Hila Levi, and @AdamYaari.
3
451
Aviv Netanyahu retweeted

I'm excited to share our #ICML2023 paper: we develop a user-informed framework for eliciting feedback to diagnose and fix policy failures.
Project page: andipeng.com/counterfactual-…. [1/8]
Machine learning systems often fail to make predictions on out-of-support data, even when it has significant structure. Our #ICLR23 paper proposes a method for learning predictors that extrapolate without making domain-specific assumptions.
arxiv.org/abs/2304.14329

We demonstrate our method's capabilities on various regression tasks and robotics imitation learning tasks, such as action prediction for picking and placing an object at a target with a robotic arm.
Joint work with @abhishekunique7, Max Simchowitz, @KaiqingZhang and @pulkitology
Drop by our poster on Tue 11:30am - 1:30pm CAT!
iclr.cc/virtual/2023/poster/…
1
12
1,256