

uiuc special interest group for robotics | making robots go brrr, creators of LeKiwi if you'd like to sponsor us, dm or email [email protected]
urbana, il
Joined November 2024
- Tweets91
- Following92
- Followers816
- Likes389





sigrobotics retweeted

Day 29/365 of robot learning.
I'm trying to get my robot arm to bounce a ping pong ball using zero real-world demos, purely through sim-to-real transfer. Hoping to get it working this weekend if it's even possible!
Got the idea from @sigrobotics, so shoutout to them!


Day 28/365 of robot learning.
Today I spent some more time experimenting with PPO and trained two policies from scratch in PyTorch using Isaac Lab: a drone learning to fly toward different targets, and another robot learning to defend against soccer shots.
For the drone, I trained 4,096 environments in parallel on a gpu, reaching a 100% success rate. The reward shaping was pretty fun to debug because the policy would find ways to maximize rewards while completely ignoring some basic things I hadn't accounted for. For example, in one experiment, the drone would reach its target properly but start spinning uncontrollably because I hadn't penalized rotation. Adding a penalty for body rotation helped fix this.
It also made me think more about how hard it is to design proper evals, benchmarks, and reward functions that capture the behaviors we want from robots. Just because a policy performs well on these metrics doesn't necessarily mean it'll generalize to different environments during deployment. I guess this is also why research on policy steerability is pretty important in robotics, since being able to correct a policy's behavior during deployment could help account for things we didn't anticipate during training.
I'm also finally done with exams, so I want to take this a step further and try something more challenging. I'm planning to experiment with sim-to-real transfer and see if I can get my robot arm to perform some tasks zero-shot, without any additional real-world training.
Humans should be more coordinated than robots.
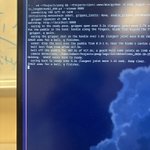
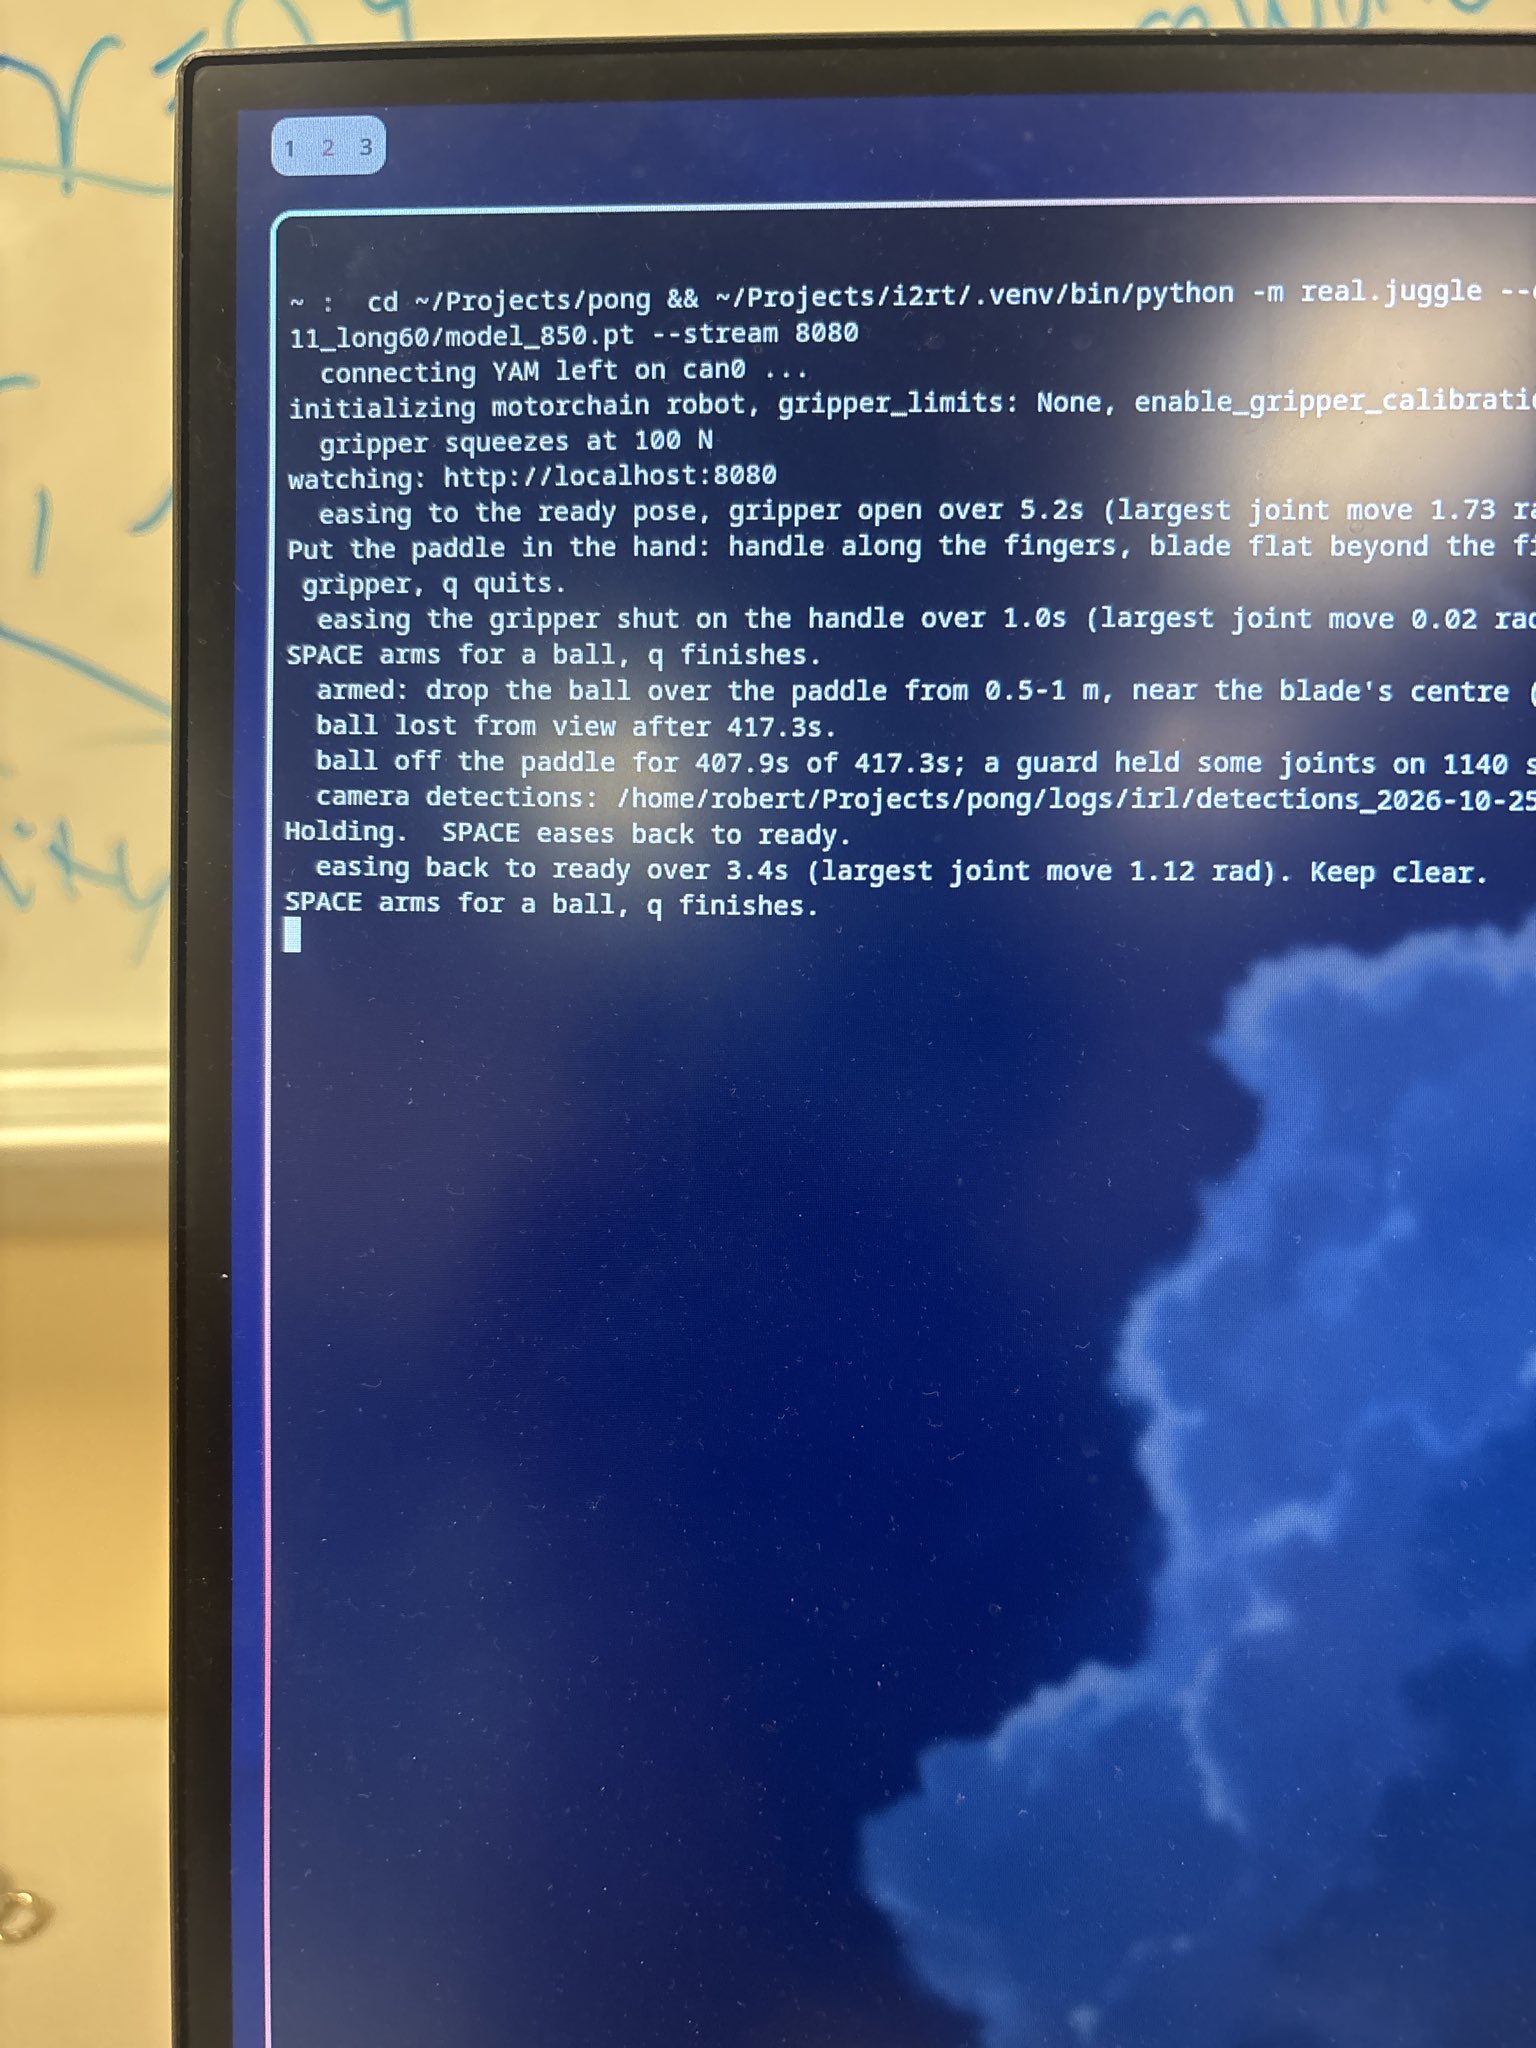
Not at at SIGRobotics though. @_robert_molina trained one of our robotic arms to keep a ping-pong ball bouncing on a paddle for up to 7 minutes using RL.
Watch the time-lapse, it just keeps going.
Our BCI team is moving quick! This is an awesome working demo

Been working on some cool stuff with the BCI team at @sigrobotics !
We got the Chrome Dino game to jump by flexing our biceps using EMG signals to test our data recorder.
Huge shoutout to the team for making this happen! @a2th2tn @AVMishra08 @sids347 @rzheng1232

sigrobotics retweeted

Been working on some cool stuff with the BCI team at @sigrobotics !
We got the Chrome Dino game to jump by flexing our biceps using EMG signals to test our data recorder.
Huge shoutout to the team for making this happen! @a2th2tn @AVMishra08 @sids347 @rzheng1232
Check out our BCI team. They got their EEG electrodes up and running and it can now pick out eye-movement blinking signals. It proves the hardware works and the procedure is dialed. Next up: mind control 🧠
Massive congratulations to @leo_lin6 and Jay Moon for winning the Best Paper Award at the RSS26 Dexterous Manipulation Workshop! 🎉
CRAFT: A Tendon-Driven Hand with Hybrid Hard-Soft Compliance
Our very own, pushing the boundaries of robotic hands! 🦾


Here's the link to their paper:
arxiv.org/abs/2603.12120

sigrobotics retweeted

Excited to finally reveal this project, me and jay at @sigrobotics have been working on this tendon-driven hard-soft hand for quite a while!

CRAFT hand🫳
1. Achieves all 33/33 dexterous grasps > 2x-20x $$ hands!
2. < $600
3. Handles fragile objects
4. Durable under contact
5. Open-sourced craft-hand.github.io/
@leo_lin6 & @shivanshpatel35 (on market; hire him🚀) will happily share anything else that you may need. Details in 🧵
🌟 Big shout out to @kenny__shaw (Leap & v2), @irmakkguzey (RUKA), @orcahand (ORCA), and many others who helped build this open research community. Thank you!
First day of Engineering Open House at @uofigrainger was a success! The kids are loving the Booster Bot!

The SigRobotics team has officially touched down in SF for @ycombinator's RoboHacks. They don't need beds, they came to build, not sleep. Let’s get it.

sigrobotics retweeted

Just finished our mock hand for Engineering Open House, a single-gear clamp driven by a Dynamixel motor. Not quite jazz hands yet, but it grips. Slapping it on our humanoid bot for now while we design the 3-finger dexterous hand next. The robot uprising is coming! 🤖 #robotics

Great to see @BitRobotNetwork using LeKiwi for their new project TeleArms!

We kept hitting the same wall: expensive hardware, limited access, and autonomy experiments stuck inside the lab. So we teamed up with @frodobots and @LeRobotHF to change that.
Introducing the Earth Rover Mini+ : a <$300 open-source autonomous rover that’s already driving in cities worldwide. With 7TB+ of real teleop data and seamless LeRobot integration, you can train and deploy policies remotely over 4G in minutes.
No more “sim-only” constraints.
No more wondering where or how to deploy.
Just real robots, real streets, real data and its completely opensource
Start building on Earth Rover now
And a special shoutout the team who made this happen at SIGRobotics:
@saketh0621 @SomrishiB @Hassoonu618 @MittalAarsh

We're open-sourcing our Earth Rover platform with @huggingface & @sigrobotics!
🤖 Integrated hardware (electronics, software, 3D files) with @LeRobotHF
🌎 7,000 hours of driving data from 40+ cities, curated by UC Berkeley researchers
Thread ↓
Thanks @mehul for hosting our visit @maticrobots last weekend. We learned a lot and it was awesome seeing everything that went into the Matic robot's design. Seeing yall's journey has been really motivating for us building projects at SigRobotics.


Last weekend, 13 SIGRobotics students flew from the cornfields to San Francisco to participate in two different robotics hackathons…
And we won awards at both! Our project “Performative”, a matcha-making robot, won first place at the Seeed Studio x NVIDIA Hackathon. Our project for Calhacks 12.0, MARC (Marker Actuated Robotic Controller), got us second place in the robotics track. 📷


The MARC team built a system that takes natural-language prompts and turns them into real pen-on-paper drawings. The system uses an LLM for image generation to create artwork from a user's prompt and then converts it into precise motion commands. Then, an SO-100 robotic arm follows the commands to physically sketch the image. Submission: devpost.com/software/marc-ma…

Congratulations to everyone who participated! Performative: @leo_lin6 @MittalAarsh @keshavbadrinath @Ezimakyu @sanjitkmr112 @filipbuilds @Hassoonu618 @HimankHanda
MARC: Krish, Tanish, william, Yash
And of course a huge thank you to the organizers and sponsors of both hackathons (shoutout @nvidia @huggingface @livekit @BitRobotNetwork @seeedstudio)
sigrobotics retweeted

Ecstatic to announce that my team and I at @sigrobotics won the #EmbodiedAIHackathon, hosted by @NVIDIARobotics, @huggingface, and @seeedstudio the past weekend!
Loved meeting everyone there and seeing other fantastic projects! Hope to see y'all at @hackwithtrees 👀
