

বাংলাদেশসহ বিশ্বের সকল বাংলা ভাষাভাষী মানুষের জন্য @axisrobotics Community. Building robotic intelligence together 🤖
Joined July 2026
- Tweets301
- Following19
- Followers327
- Likes351




Pinned Tweet
Axis এখন একটি Model Company হিসেবে এগিয়ে যাচ্ছে।
আমরা Data Infrastructure তৈরি করেছি একটি লক্ষ্য নিয়ে- General Robotic Intelligence তৈরি করা।
আমাদের পদ্ধতির মূল ভিত্তি হলো Skill। আমরা Reinforcement Learning-এর মাধ্যমে তৈরি expert-দের দক্ষতাকে reusable ও conditioned skill-এ রূপান্তর করি। এরপর এই skill-গুলো একটি General Model তৈরিতে কাজে লাগে।
Data হলো input, আর Model হলো product। এই Model নিজের তৈরি output থেকেই ক্রমাগত উন্নত হতে থাকে। Model যত উন্নত হবে, General Robotic Intelligence-এর সম্ভাবনাও তত বাড়বে।
আমাদের যাত্রা সবে শুরু।


Axis is scaling into a model company.
We built the data infrastructure for one reason: to produce general robotic intelligence.
Our approach is centered on skill: we turn reinforcement learning experts into reusable, conditioned skills, and those skills feed a general model.
Data is the input. The model is the product, and it keeps improving on its own outputs. As it grows, the ceiling keeps rising toward general robotic intelligence.
We're just getting started.

2
7
174
Axis Sim-Lab Training আসছে!
Axis Bangladesh কমিউনিটির জন্য আয়োজন করা হচ্ছে একটি লাইভ ট্রেনিং সেশন।
এই সেশনে আমরা শিখব কীভাবে Axis Hub-এ Simulation Tasks সম্পন্ন করতে হয়, কীভাবে রোবট অপারেট করতে হয় এবং সাধারণ ভুলগুলো এড়িয়ে আরও ভালোভাবে কাজ করা যায়।
🎙️ Host: @Ashik_80
⏱️ Duration: 30 Minutes
📍 Platform: Discord
সেশনে যা থাকছে:
- Axis Hub-এর পরিচিতি ও ব্যবহার
- Robot Operation এবং Live Practical Demonstration
- অভিজ্ঞ Contributors-দের Tips & Tricks
- Q&A এবং Community Feedback
নতুন হোন বা অভিজ্ঞ Contributor, সবার জন্যই এই সেশনটি হতে যাচ্ছে শেখার এবং নিজেদের দক্ষতা বাড়ানোর দারুণ একটি সুযোগ।
সবাইকে অংশগ্রহণের আমন্ত্রণ!

আমরা Visual Policy Distillation-এর জন্য ODE Policy ব্যবহার করছি এবং শুরুতেই বেশ ভালো ফলাফল পেয়েছি।
Action কীভাবে সময়ের সঙ্গে পরিবর্তিত হয়, তা শেখার মাধ্যমে Policy স্বাভাবিকভাবেই Robot-এর Motion-এর ধারাবাহিকতা (Continuity) বুঝতে পারে।
ভিডিওতে দেখা যাচ্ছে, আমাদের Franka Robot Simulation-এ একটি Bolt-এর ওপর Nut লাগানোর কাজ শিখছে। SGS থেকে পাওয়া Task-টি Robot সফলভাবে পুনরায় সম্পাদন করছে।
পরবর্তী পরিকল্পনা হলো, ODE Policy ব্যবহার করে আরও বিস্তৃত Assembly Skill Distill করে এমন Policy তৈরি করা, যা সরাসরি Camera Image থেকে কাজ করতে পারবে।
এর মধ্যে রয়েছে Gear Fitting, Peg Insertion এবং Connector Joining-এর মতো বিভিন্ন Assembly Task।
We’ve been using ODE Policy for visual policy distillation, with strong early results. Learning how actions evolve over time gives the policy a natural way to capture the continuity of robot motion.
In the video, our Franka robot learns to thread a nut onto a bolt in simulation, reproducing the task from SGS.
Next, we plan to use ODE Policy to distill a wider range of assembly skills into policies that act from camera images, from fitting gears and inserting pegs to joining connectors.
5
142
Real Robot Data সীমিত হলে Sim-to-Real Policy Co-training-এর জন্য কীভাবে সঠিক Simulation Demonstration নির্বাচন করা উচিত?
পরিচয় করিয়ে দিচ্ছি TUCO: Curating Simulation Demonstrations for Sim-to-Real Robot Policy Co-Training।
এটি Sim-to-Real Robot Policy Co-training-এর জন্য Data Curation নিয়ে প্রথম Systematic Study।
প্রতি Task-এর জন্য মাত্র ১০টি Real Demonstration এবং বাছাই করা ৬০০টি Simulation Demonstration ব্যবহার করেই TUCO Real Robot-এ ৮৫.৮% Success Rate অর্জন করেছে। অন্যদিকে, সম্পূর্ণ ১,২০০টি Simulation Data Pool অথবা Randomly Selected ৬০০টি Demonstration ব্যবহার করে Success Rate ছিল মাত্র ২৫.৮%।
এছাড়া, তিনটি Transfer Setting-এর সবগুলোতেই TUCO নতুন State-of-the-Art (SOTA) অর্জন করেছে।
এই গবেষণায় সহযোগিতা করেছেন নিচের বিশ্ববিদ্যালয়গুলোর গবেষকরা:
@Stanford @NTUsg @CarnegieMellon @FudanUniversity @UCBerkeley @sjtu1896
Project Page: tuco-curation.github.io/
বিস্তারিত নিচে দেওয়া হলো। ⬇️
How should you choose simulation demos for co-training when real robot data is scarce?
Introducing TUCO: Curating Simulation Demonstrations for Sim-to-Real Robot Policy Co-Training, the first systematic study of data curation for sim-to-real robot policy co-training.
With just 10 real demos and 600 curated sim demos per task, TUCO hits 85.8% real-robot success, versus 25.8% for the full 1,200 pool or a random 600, and sets SOTA across all three transfer settings.
A collaboration with researchers from @Stanford @NTUsg @CarnegieMellon @FudanUniversity @UCBerkeley @sjtu1896.
Project page: tuco-curation.github.io/
Details below ⬇️
1
3
117
5/6 Simulation Experiments
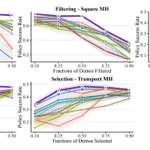
একই Protocol অনুসরণ করে তিনটি আলাদা Seed-এর ফলাফলের গড় নিয়ে দুটি Simulation Setting-এ TUCO-এর কার্যকারিতা যাচাই করা হয়েছে।
১. Single-Simulator (RoboMimic)
এখানে Source এবং Target দুটিই একই Simulator ব্যবহার করে। ফলে Domain Gap-এর প্রভাব বাদ দিয়ে শুধু Data Curation Criterion-এর কার্যকারিতা যাচাই করা সম্ভব হয়েছে।
Lift, Square এবং Transport এই তিনটি Task-এর মোট ২৫টি Task-Budget Setting-এর মধ্যে ১৮টিতে TUCO সেরা অথবা যৌথভাবে সেরা ফলাফল করেছে। শুধু ২৫% Data ব্যবহার করেই Lift Task-এ সম্পূর্ণ Data দিয়ে Training করার সমান ফলাফল অর্জন করেছে।
২. Sim-to-Sim (IsaacSim থেকে MuJoCo)
এখানে একটি Simulator-এ Demo তৈরি করা হয়েছে এবং অন্য Simulator-এ সেগুলো Evaluate করা হয়েছে। এটি Sim-to-Real Gap-এর একটি নিয়ন্ত্রিত বিকল্প হিসেবে কাজ করে।
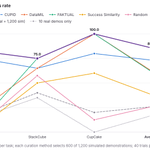
মোট ১৮টি Setting-এর মধ্যে ১৫টিতে TUCO সেরা ফলাফল করেছে এবং সব ১৮টিতেই Random Selection-এর চেয়ে ভালো করেছে।
এমনকি সম্পূর্ণ IsaacSim Data Pool ব্যবহার করায় CupCake Task-এর ফলাফল আরও খারাপ হয়েছে। অন্যদিকে, সঠিকভাবে Curate করা Data Subset প্রতিটি Task-এই সেরা ফলাফল দিয়েছে।


1
1
3
6/6
যখন Real Data সীমিত থাকে, তখন Simulation Data-এর পরিমাণের চেয়ে সঠিকভাবে Data নির্বাচন করাই বেশি গুরুত্বপূর্ণ।
Influence-based Utility এবং Coverage ব্যবহার করে Closed-loop পদ্ধতিতে এমন Demo নির্বাচন করা যায়, যেগুলো বাস্তব Robot-এ সত্যিকার অর্থেই ভালোভাবে Transfer হয়।
Project Page: tuco-curation.github.io
Paper: arxiv.org/abs/2610.05407
Code: github.com/Z-yiwei/tuco

1
3
base:0x5be75e3b0aff5d1a042a5363ae36acb1d6d755ea Staking চালু হয়েছে @HTX_Global-এ
এখানে সর্বোচ্চ 150% APY পাওয়ার সুযোগ রয়েছে।

Subscribe to the AXIS NewList!
Enjoy up to 150% APY:
- Subscriptions are now OPEN
- Maximum allocation: 70,000 AXIS
@axisrobotics
Start NOW 👉htx.net.im/en-us/support/750…

3
38
আমরা একটি Multi-layered Robotics Architecture তৈরি করছি, যেখানে LLM উচ্চপর্যায়ের Reasoning এবং Skill Harness পরিচালনা করে।
এখানে একটি Demo দেখানো হয়েছে। Task ছিল: Right Arm ব্যবহার করে Tray থেকে তিনটি Object তুলে Table-এর X-axis বরাবর একটি সারিতে সাজানো, যেখানে সবচেয়ে লম্বা Object থেকে সবচেয়ে খাটো Object পর্যন্ত ক্রমানুসারে থাকবে।
এখানে দেখা যাচ্ছে, Agent কীভাবে Skill Harness-এর মাধ্যমে Task-টিকে ধারাবাহিক Motion-এ রূপান্তর করছে। Scene Understanding, উচ্চতা অনুযায়ী Object সাজানো এবং Placement Planning-এর মতো ধাপগুলোকে Physical Execution-এর সঙ্গে যুক্ত করছে।
এটি আমাদের জন্য একটি দারুণ সম্ভাবনাময় শুরু।
We're building a multi-layered robotics architecture, where the LLM drives high-level reasoning and skill harness.
Here's a demo. The task: use the right arm to arrange three objects from the tray in a row along the X axis of the table, ordered by height from tallest to shortest.
You can see the agent turn the task into continuous motion through skill harness, linking scene understanding, height-based ordering, and placement planning to physical execution.
This is an exciting start.
1
5
99
base:0x5be75e3b0aff5d1a042a5363ae36acb1d6d755ea Token Buyback ঘোষণা
আমাদের Data Engine বাস্তব জগতের বিভিন্ন ক্ষেত্রে Physical AI Applications-কে শক্তিশালী করছে। আমরা চাই, প্রতিটি Contributor যেন এর সুফল সরাসরি পেতে পারেন।
এজন্য আমরা base:0x5be75e3b0aff5d1a042a5363ae36acb1d6d755ea Token Buyback চালু করছি। ইতোমধ্যে প্রথম $150K-এর Buyback সম্পন্ন হয়েছে।
১. আমাদের Commercial Deal-গুলো Pilot-first Model অনুসরণ করে। সফল Pilot সম্পন্ন হওয়ার পরই Framework Agreement স্বাক্ষর করা হয় এবং নির্ধারিত Delivery Milestone অনুযায়ী ধাপে ধাপে Payment দেওয়া হয়।
২. এখন থেকে আমাদের Commercial Contract থেকে অর্জিত Net Profit-এর একটি অংশ Payment সংগ্রহের সঙ্গে সঙ্গে base:0x5be75e3b0aff5d1a042a5363ae36acb1d6d755ea Buyback-এর জন্য বরাদ্দ করা হবে।
প্রতি Quarter-এ একটি Public Buyback Report প্রকাশ করা হবে। পাশাপাশি On-chain Treasury Record সবার জন্য উন্মুক্ত থাকবে, যাতে যে কেউ নিজে থেকেই তা যাচাই করতে পারেন।
Buyback-এর মাধ্যমে পুনরায় কেনা সব base:0x5be75e3b0aff5d1a042a5363ae36acb1d6d755ea Public Treasury-তে পাঠানো হবে।
Treasury Address: 0xfC8c6ABC0742E64c13d6B0bAC1fCD7e604eC7Dc5
সম্পূর্ণ বিস্তারিত দেখুন: docs.axisrobotics.ai/economi…

Announcing the $AXIS Token Buyback
Our data engine is powering Physical AI applications across real-world scenarios. We want every contributor to share directly in it.
We're launching the $AXIS token buyback, with our first $150K tranche already complete.
1. Our commercial deals follow a pilot-first model. Framework agreements are signed only after a successful pilot, and payments are released in tranches against delivery milestones.
2. Going forward, a portion of the net profit from our commercial contracts is allocated to buy back $AXIS as cash is collected.
A public buyback report is published each quarter, with on-chain treasury records anyone can independently verify. All repurchased $AXIS is transferred to the public treasury.
Treasury address: 0xfC8c6ABC0742E64c13d6B0bAC1fCD7e604eC7Dc5
See the full details: docs.axisrobotics.ai/economi…

প্রতিটি ধাপ On-chain-এ যাচাই করতে পারবেন:
TWAP Order: explorer.cow.fi/base/twap/17…
Treasury Transfer: basescan.org/tx/0x71cfbe3d27…

9
বাংলাদেশ কমিউনিটি Q&A ইভেন্ট সম্পন্ন!
Axis Bangladesh Community-এর উদ্যোগে আমাদের কমিউনিটি Q&A ইভেন্টটি সফলভাবে সম্পন্ন হয়েছে।
HOST: @Ashik_80
এই আয়োজনের মূল উদ্দেশ্য ছিল কমিউনিটির বিভিন্ন প্রশ্ন, বিভ্রান্তি ও উদ্বেগের বিষয়ে স্পষ্ট ধারণা দেওয়া এবং Axis-এর প্রতি সদস্যদের আস্থা ও বিশ্বাস আরও দৃঢ় করা।
আলোচনায় উঠে এসেছে:
- Axis Season 2 (S2) এবং ভবিষ্যৎ পরিকল্পনা।
- Reinforcement Learning (RL) কী এবং কেন Axis Expert ও Distillation Data-এর ওপর গুরুত্ব দিচ্ছে।
- সাম্প্রতিক সময়ে base:0x5be75e3b0aff5d1a042a5363ae36acb1d6d755ea টোকেনের মূল্য কমে যাওয়ার সম্ভাব্য কারণ।
- কমিউনিটির বিভিন্ন প্রশ্ন, মতামত, পরামর্শ ও উদ্বেগ।
আমরা বিশ্বাস করি, এমন খোলামেলা আলোচনা কমিউনিটির মধ্যে স্বচ্ছতা, বোঝাপড়া ও পারস্পরিক বিশ্বাস বাড়াতে গুরুত্বপূর্ণ ভূমিকা রাখে।

Product Update 🛠️
আমরা Open Task Slot-এর সংখ্যা কমিয়ে দিয়েছি। এর পেছনে কারণগুলো হলো:
1️⃣ এখন GPT-6 সাধারণ Task-গুলো সমাধান করতে এবং সেগুলোর জন্য নির্ভরযোগ্য Trajectory তৈরি করতে পারে। সামনে আমরা একই ধরনের Repetitive Data Collection-এর কাজ আরও কমিয়ে আনব।
2️⃣ জটিল Task-এর ক্ষেত্রে High-quality Human Demonstration এখনো অত্যন্ত গুরুত্বপূর্ণ। কারণ এই Demonstration-গুলো সাধারণ Routine Trajectory-এর তুলনায় অনেক বেশি মূল্যবান।
Season 1-এ আমাদের মূল লক্ষ্য ছিল Pretraining-এর জন্য বিভিন্ন ধরনের Human Input সংগ্রহ করা। সেই ভিত্তি তৈরি হওয়ার পর এখন আমাদের ফোকাস RL, Expert এবং Distillation-এর দিকে যাচ্ছে।
Open Task Slot-এর সংখ্যা কমিয়ে আনার মাধ্যমে এই পরিবর্তনকে আরও কার্যকর করা সম্ভব হবে। পাশাপাশি, High-quality Feedback এবং বাস্তব প্রয়োগে বেশি মূল্য তৈরি করে এমন কাজের জন্য Resources কেন্দ্রীভূত রাখা যাবে।
আমাদের High-level Technical Roadmap দেখুন। ⬇️


3
58
স্বাভাবিকভাবে সংগ্রহ করা, কিছুটা অসম্পূর্ণ বা Suboptimal Robot Demonstration থেকে VLA-গুলো কীভাবে শিখবে?
পরিচয় করিয়ে দিচ্ছি AXIS-Bench: What Matters in Quality-Aware VLA Pretraining।
এটি একটি Benchmark ও Empirical Study, যেখানে VLA Pretraining-এর সময় Demonstration-এর Quality কীভাবে নির্ধারণ, Label এবং ব্যবহার করা উচিত, তা নিয়ে গবেষণা করা হয়েছে।
তিনটি VLA Model এবং ২৪টি Downstream Task-এর ওপর পরীক্ষা চালিয়ে আমরা Quality-aware Learning-এর বিভিন্ন পদ্ধতির তুলনা করেছি। গবেষণায় দেখা গেছে, সব Model-এর জন্য একই পদ্ধতি সমানভাবে কার্যকর নয়।
এই গবেষণায় সহযোগিতা করেছেন নিচের বিশ্ববিদ্যালয়গুলোর গবেষকরা: @GeorgiaTech @CarnegieMellon @UCBerkeley @NTUsg @NUSingapore @RiceUniversity @UCRiverside @TAMU
বিস্তারিত ও Companion Dataset Release দেখুন। ⬇️
How should VLAs learn from naturally suboptimal robot demonstrations?
Introducing AXIS-Bench: What Matters in Quality-Aware VLA Pretraining, a benchmark and empirical study of how demonstration quality should be defined, labeled, and used during pretraining.
Across three VLAs and 24 downstream tasks, we systematically compare quality-aware learning choices and find that no single recipe works for every model.
A collaboration with researchers from @GeorgiaTech @CarnegieMellon @UCBerkeley @NTUsg @NUSingapore @RiceUniversity @UCRiverside @TAMU.
Details & Companion Dataset Release ⬇️
1
2
64
6/7 Data Release
Axis Dataset V1 আগস্ট মাসে Launch করা হয়েছিল। এরপর আমরা Dataset V2 তৈরি করেছি, যেখানে এখন Camera Augmentation-সহ ১,০৯২টি Task এবং ২.৩৫ মিলিয়ন Episode রয়েছে।
AXIS-Bench-এ ব্যবহৃত Companion Dataset-গুলো Dataset V2 থেকেই তৈরি করা হয়েছে:
• Pretraining Dataset: ৭৩১টি Task জুড়ে ৫,০০০টি Simulated Franka Demonstration, যেখানে Quality Label এবং Frame Index যুক্ত রয়েছে।
• Benchmark Dataset: ২৪টি Held-out Task জুড়ে ৩৫৪টি Fine-tuning Demonstration। এর সঙ্গে রয়েছে Task Definition, Success Checker, Scene Assets এবং Evaluation Layouts।
• Sim-to-Real Pretraining Dataset: ৬৬৩টি Task জুড়ে ১৯,২৫০টি Replayable Simulated Episode। Real Demonstration দিয়ে Fine-tuning করার আগে নিজের Workspace-এ Re-render করে Pretraining-এর জন্য ব্যবহার করা যাবে।
এই দুটি উদ্যোগের লক্ষ্য একে অপরের পরিপূরক। Axis Data Resource-কে আরও সমৃদ্ধ করছে, অন্যদিকে AXIS-Bench গবেষণা করছে Data Quality এবং Training-এর বিভিন্ন সিদ্ধান্ত কীভাবে Downstream VLA Performance-কে প্রভাবিত করে।
teapaw.org/axisrobotics/status/20…
Introducing Axis Dataset V1 - the simulation dataset for scalable robot manipulation.
Can noisy, crowdsourced simulation data support embodied pretraining? Yes—with enough coverage and diversity.
Continual pretraining on AXIS dataset V1 lifts π0.5 from 83.9% to 88.8% on LIBERO-Plus, with performance improving consistently as the pretraining data scales from 25% to 100% of the full dataset, showing no clear saturation.
Built with researchers from @GeorgiaTech @UCBerkeley @TAMU @JohnsHopkins @Penn @UMich @NUSingapore @NTUsg.
➡️Related links:
Paper: arxiv.org/abs/2607.21588
Dataset: huggingface.co/datasets/axis…
Project Page: axisaiorg.github.io/AXIS-V1/
GitHub Codebase: github.com/AxisAIOrg/Axis-V1…
1
3
7/7 Links
AXIS-Bench এবং আমাদের অন্যান্য Data Resource ঘুরে দেখুন:
Project Resources:
Project Page: axis-bench.github.io/
Paper: arxiv.org/abs/2610.18869
Code: github.com/axis-bench/axis-b…
Try Axis Hub: hub.axisrobotics.ai/
Datasets:
Axis Dataset V2: huggingface.co/datasets/axis…
Pretraining: huggingface.co/datasets/axis…
Benchmark: huggingface.co/datasets/axis…
Sim-to-Real Pretraining: huggingface.co/datasets/axis…
আমরা আশা করি, AXIS-Bench অসম্পূর্ণ বা Imperfect Demonstration থেকে শেখার বিষয়ে আরও Reproducible Research পরিচালনায় সহায়তা করবে।
5