Building a robotics company in public. Co-founder & CEO @makermodsai backed by @fdotinc https://xitter.cf/t.co/iqxjzOSRlB
San Francisco, CA
Joined May 2019
- Tweets1.3K
- Following1.5K
- Followers3.1K
- Likes5.5K




Ryan Chan retweeted

Our @DeftRobo robots have helped build ~20,000 Tesla Model 3/Ys.
Bought one recently? Our robots likely handled its parts.
Production-deployed at a Tier 1, on robot foundation models + our deployment infra:
- 700 parts/day
- 24 hrs/day
- 100% uptime
Next: triple-digit robots
Ryan Chan retweeted

Introducing ZeroShot 🎯
AutoFAB's AI model for Robot Agent Loops
Reasons through new tasks from first principles, right on the robot
Then runs on repeat from memory, faster and cheaper
Available today: autofab.net
Ryan Chan retweeted

Dear algo, please show this tweet only to founders bellow 200 followers building cool shit
Ryan Chan retweeted

Robots are getting better at completing tasks. But what happens when they make a mistake?
We fine-tuned π₀.₅ on two real-world manipulation tasks to showcase whether recovery demonstrations can improve policy reliability more effectively than additional successful demonstrations. 🧵

Ryan Chan retweeted

tired of packing up your tools after using them? just get @dreamlabs_ai dream-1 and the @makermodsai metal arm to do it
Ryan Chan retweeted

Robot metal arms from MakerMods have arrived and assembling them with @willwarren onto our coffee table. Excited to train it and learn a lot!

Ryan Chan retweeted

These guys are really forward forward deployed @makermodsai @IsaacSin12 @Ryan_Resolution 🤯
Thanks for the unboxing experience time to benchmark tf out of you 😊

Ryan Chan retweeted
Humanoid hardware is like iPhone 1 right now. Shitty but usable by enthusiasts
2026-2028 we will get to IPhone 4 level. Usable but lowkey missing ecosystem and software (intelligence) polish
By then low-hanging fruits like overheating on regular use, unreasonable inaccuracies/jitter will be solved. It no longer bottlenecks basic deployment.
From then onwards it’s a loooooong tail of intelligence, hardware, ecosystem improvements. Its going to be a marathon.
Ryan Chan retweeted

We just served 1.5M inference calls across 400 cities and 60 countries in the 4 days since launch! Thank you all for the support!
Let Dream-1 control your robot today ☁️ dreamlabs.ai/
Ryan Chan retweeted

This is the best place to build hardware 🌎
Robotic arms, actuators, flying cars, autonomous CNCs, and more...
Last Friday, we invited investors onto our campus to see what these 30 new teams have been building.
DM us if you want an invite to the next one.
Ryan Chan retweeted
Hardware is becoming a team sport.
@IsaacSin12 and @Ryan_Resolution built a $999 robot arm.
@Jonnysdoes built a device that understands objects and projects onto them.
Now imagine 100 hardware founders under one roof:
Ryan Chan retweeted
The fastest way to try Dream-1 on your own robot arms:
playground.makermods.ai
Plug your arms into a laptop, open Chrome, type a task. Nothing to install: no Python, no ROS, no drivers
No arms yet? Buy one from makermods.ai
How it works 👇
The whole robot stack runs in a browser tab. Servo drivers, calibration, cameras, the control loop and IK are all TypeScript. The tab talks to your arms over Web Serial. Dream-1 runs in the cloud, everything that touches the robot runs in your browser.
We wrote the SO-101's Feetech STS3215 servo protocol from scratch in TypeScript, packet by packet at 1 Mbaud. Two background threads split the work. One owns the serial ports and runs a 20 Hz control loop. The other handles the cameras, the Dream-1 calls and the IK.
Setup takes a few clicks:
- Swing to find: move each arm by hand and the console watches every USB port to see which one moved. No guessing /dev/tty names.
- Auto-calibrate: motors drive each joint to its end stops, write the result to the servos' memory, and line it up with Dream's reference arm. Both arms calibrate at once.
Dream-1 outputs hand poses, not joint angles, so something has to turn them into joint commands. We ported Dream's own trajectory IK solver to TypeScript. It solves each full 48-step action chunk at once, with velocity, acceleration and jerk limits, and it's checked against the Python SDK's output.
No arm yet? The same page runs a MuJoCo physics sim in the browser, compiled to WebAssembly. Prompt Dream-1 on virtual arms first. Works with SO-101, Maker Arm and Metal Arm.
try it out yourself -> playground.makermods.ai
Ryan Chan retweeted

Introducing Junfan Labs @junfanlabs.
Physical AI doesn't wait for Saturday. Neither will I.
For 35 editions of @saturdayrobotic, I've brought researchers and founders together to explore the papers shaping robotics and world models.
Building this community has taught me how to understand the field—and where reading stops.
You can't read your way to knowing whether a robot actually works. You have to test it on real hardware, understand where it fails, and produce evidence that researchers, companies, and investors can act on.
A club reads. A lab proves.
I'm building @junfanlabs around this conviction.
Research. Real-world evaluation. Technical advisory. Industry partnerships.
One goal: close the gap between what AI systems claim to do and what they can reliably do in the physical world.
The opportunity isn't just to build better robots. It's to build better ways to understand, evaluate, and deploy them.
I'm continuing to lead @saturdayrobotic while building @junfanlabs as a platform for deeper research, real-world evaluation, and industry collaboration.
One brings the community together around frontier research. The other extends that work into new research, technical partnerships, and real-world applications.
Both are part of the same mission: advancing Physical AI beyond what looks impressive on paper or in a demo.
The next chapter starts now. 🔬
#PhysicalAI #Robotics #WorldModels #EmbodiedAI #JunfanLabs #SaturdayRobotics #JunfanZhu

Ryan Chan retweeted

Introducing Product Hunt for agents.
The leaderboard of the most popular tools agents are using today.
monid.ai/rankings
Ryan Chan retweeted

Great working together with @jerthesquare_ again in @dreamlabs_ai =))

Ryan Chan retweeted

After working on Dream-1 for the last 4 months, here's my take:
LLMs vs WAMs isn't the right framing. A model like Dream-1 will soon be a tool call for LLMs, and that gets more feasible as LLMs inevitably get faster and cheaper.
Two things we didn't put in the blog post🧵👇

Ryan Chan retweeted

officially retiring the crash mattresses
drastically reduced our control parameters and built a much simpler flight controller
much better stability and actual controlled landings with zero broken parts
Ryan Chan retweeted

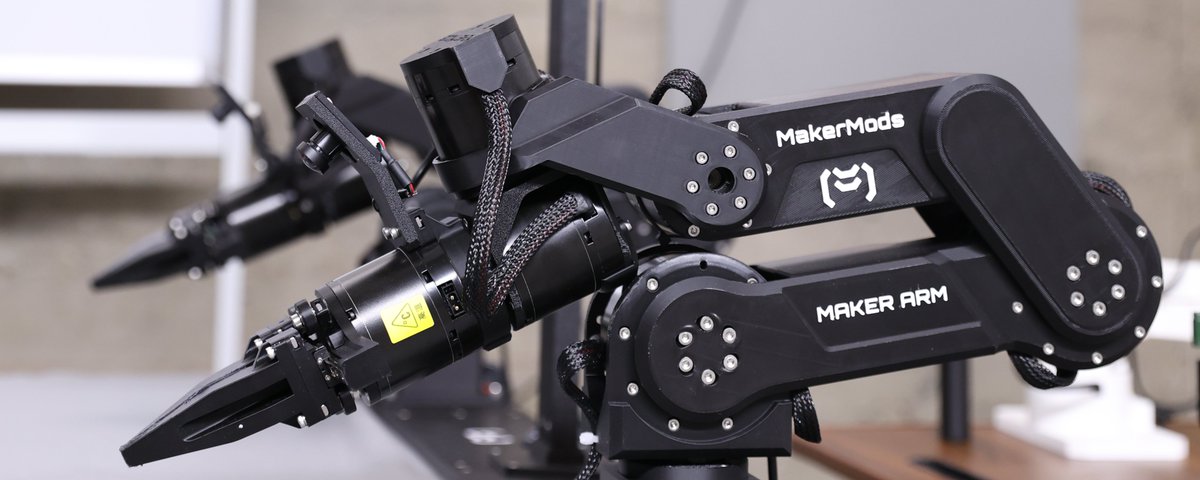
Huge shoutout to @Ryan_Resolution and the MakerMods team for launching Maker Arm — the accessible open-source 6DoF robot arm powered by RobStride QDD actuators, now running Dream-1 from Dream Labs.
This project solves a key pain point in embodied AI: expensive, hard-to-source robot hardware. We were glad to support the team to deliver reliable QDD actuators for this launch. Open, affordable hardware is how we bring zero-shot physical AI to more builders and researchers.
#RobStride #QDDActuator #MakerArm #PhysicalAI #Dream1 #actuator